LLM reasoning
Interprets the operator’s objective and connects it to mission decisions and responses.
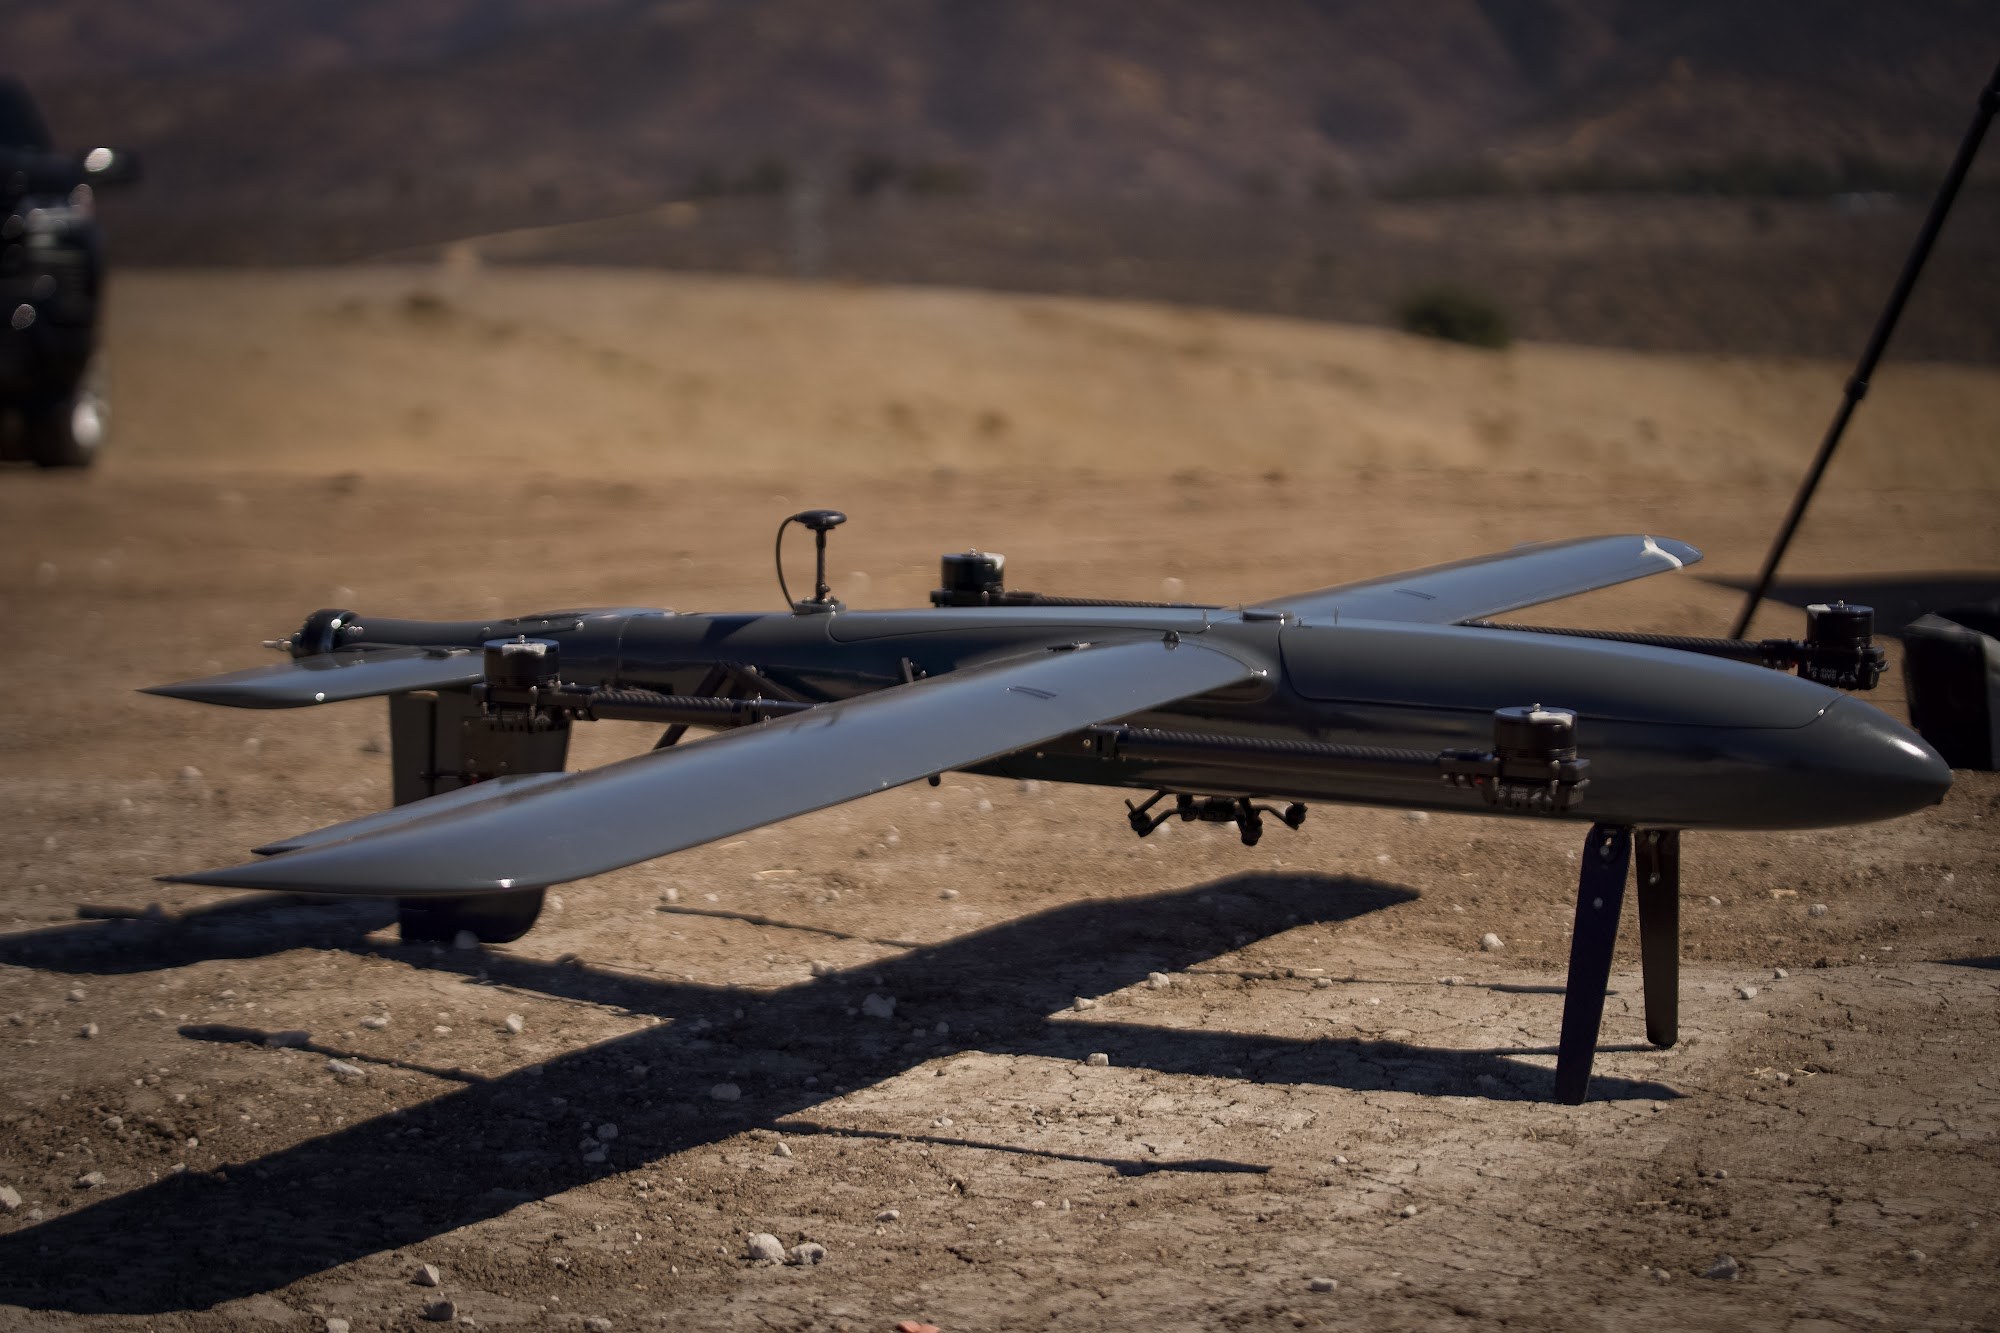
One aircraft. An onboard intelligence system.
A mission that begins with your intent.
Describe the objective in natural language. Degla connects the instruction to onboard reasoning, visual perception and the aircraft’s mission loop.
NVIDIA Jetson Thor T5000 powers the current onboard mission stack. Reasoning, perception and mission execution run on the aircraft, including full offline missions.
Interprets the operator’s objective and connects it to mission decisions and responses.
Interprets camera scenes in the context of the mission, connecting what is visible to the task.
Supports object detection and continued observation of people and vehicles in the field.
Supports navigation when GPS is unavailable, within the onboard mission and flight-control loop.
System overview. Recordings show their individual field sessions and viewpoints.
Aircraft-camera footage, ground deployments and the operator’s interface. Each clip includes its context and available resolution.
The three full-resolution tracking recordings retain 1920 × 1080 resolution. Other clips retain their native 1080p or 720p resolution, including vertical recordings. Open any clip for its full frame and sound, where supplied.
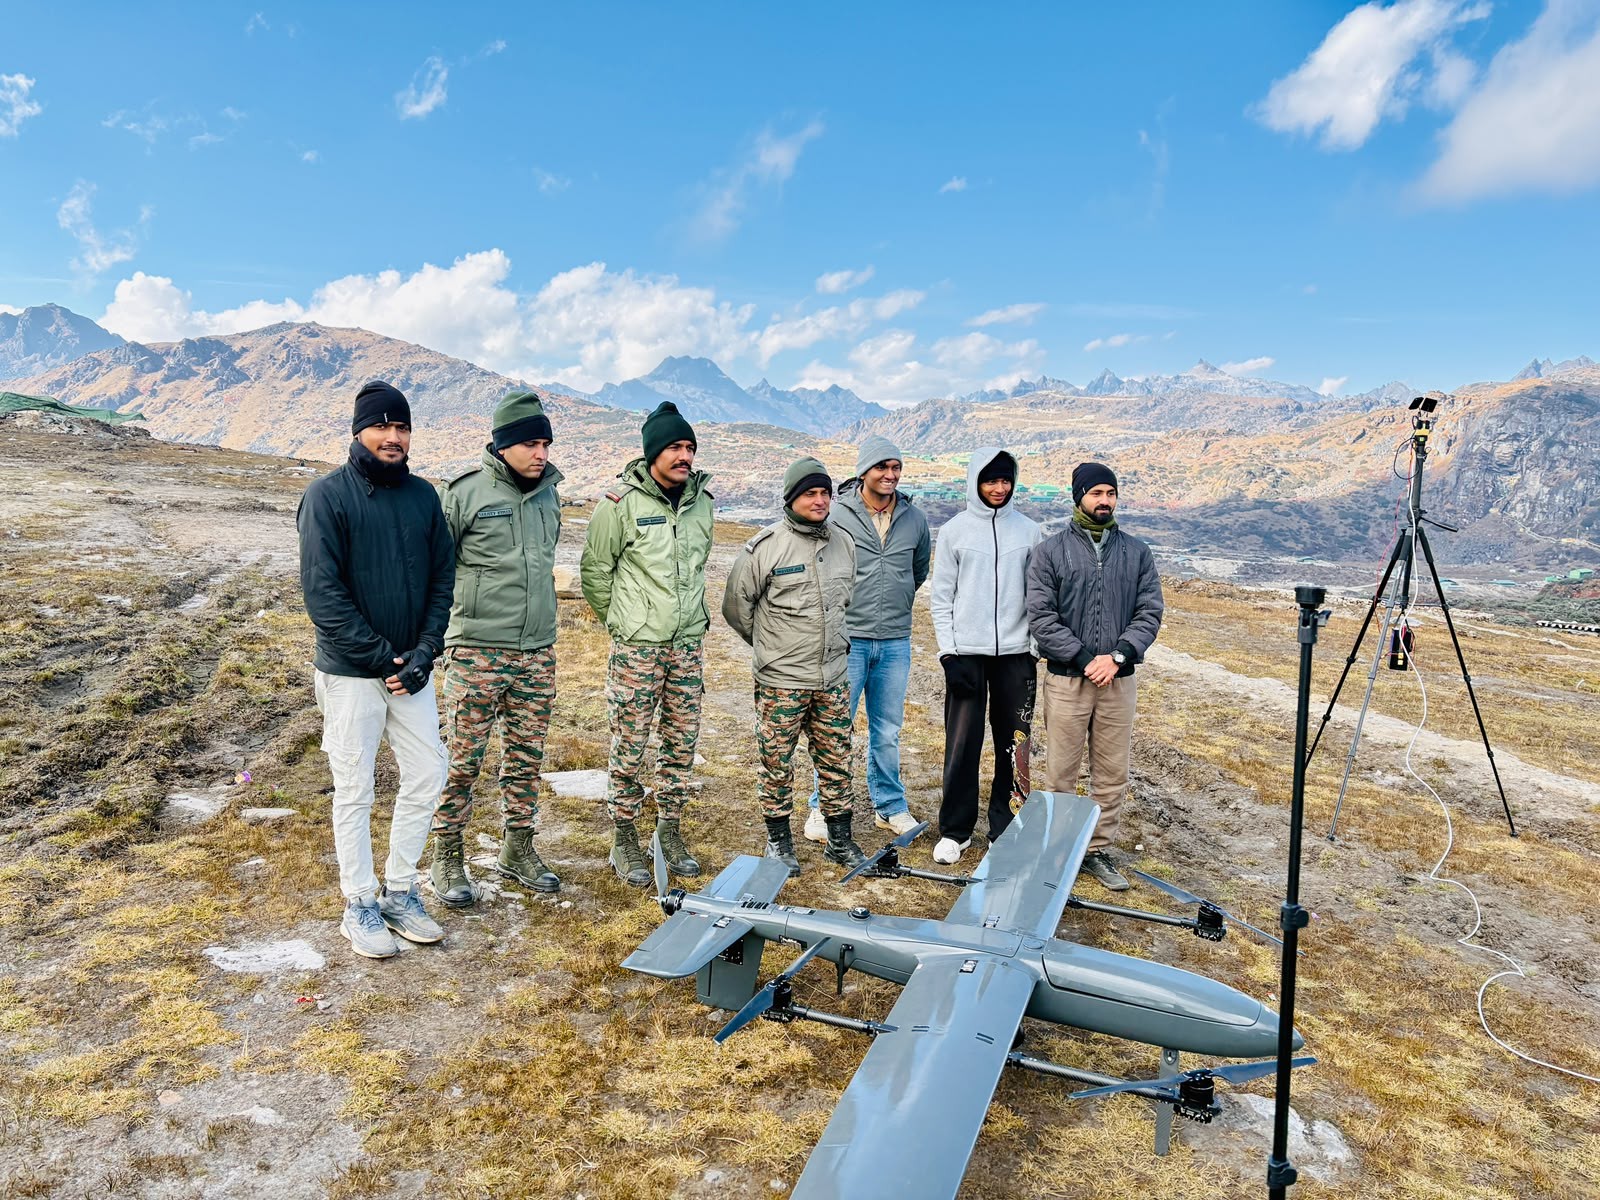
Degla is being used for border control and monitoring at the India–China border. This field media brings together the aircraft, deployment team, vehicle and person tracking, and the operator’s ground station.
India deployment photographs, San Diego deployments and the SAR command station. Open a photograph to see the complete image.
Explore the technology, watch the field media, and talk to the team.